KestrelCV
Flight-demonstrated NVIDIA Jetson · NXP i.MX Dual-use EU + NATO
The airframe is replaceable.
The perception layer is the product.

A portable onboard mission payload that adds real-time perception to standard UAV carriers — detecting, tracking and visualising mission-relevant objects directly onboard, over the existing video link. No cloud. No platform lock-in.

▶Flight gallery
scroll ↓
01 · Problem

A UAV can see the scene.
Holding what matters is still a human job.

The perception gap sits inside the loop — between a live feed and a confident, held target.

Operator load

Eyes on a laggy feed

The operator hunts, identifies and holds the object by hand over the video link — under stress, wind and a moving airframe. Miss a frame, lose the track.

Contested links

No cloud at the edge

Server-side AI is unusable where it matters: jamming, latency and lost link. The perception has to live on the aircraft, not in a datacenter.

Wrong AI

Off-the-shelf can't see from above

Generic detectors are ground-trained. Small, oblique, top-down objects slip through — and they false-fire on rooftops and field texture.

02 · Solution

What KestrelCV does

A portable onboard perception layer that rides the aircraft — detect many, track one, assist the operator, all onboard.

Detect many

A live sensor plot

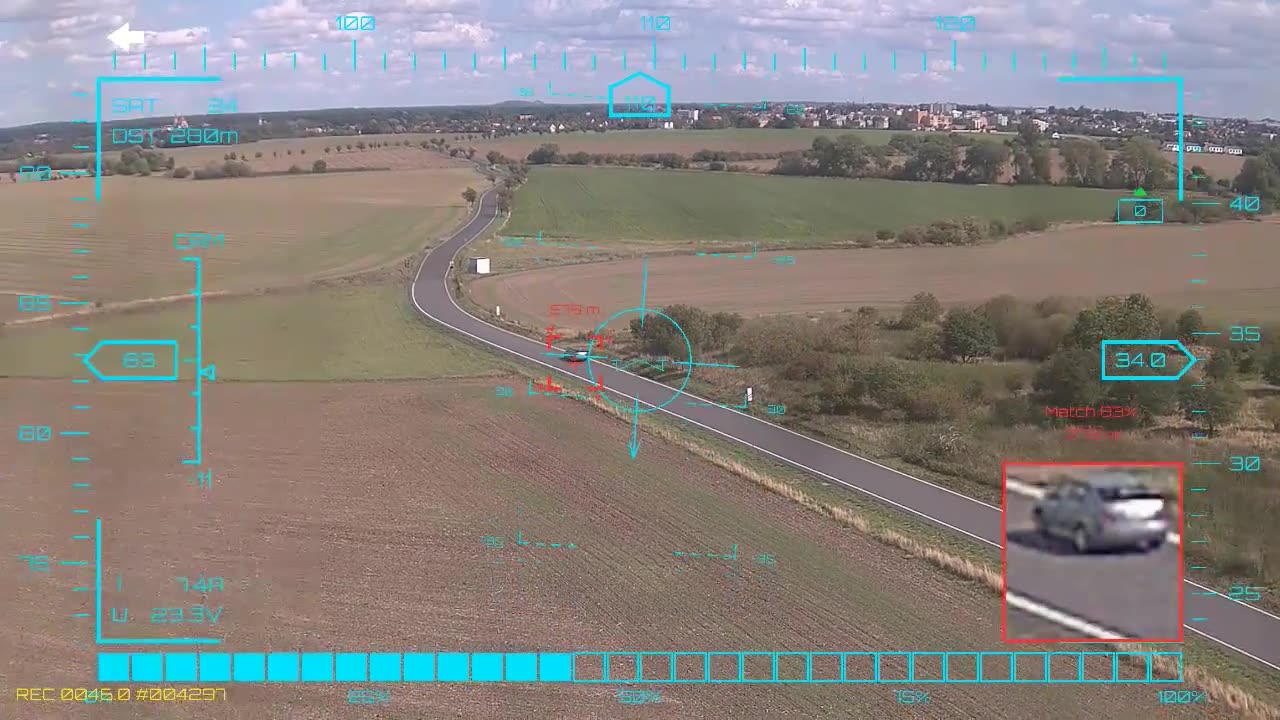
Whole-frame detection marks supported object classes across the scene in real time with a clean reticle — a live plot, not screen clutter.

Track one

Lock & hold

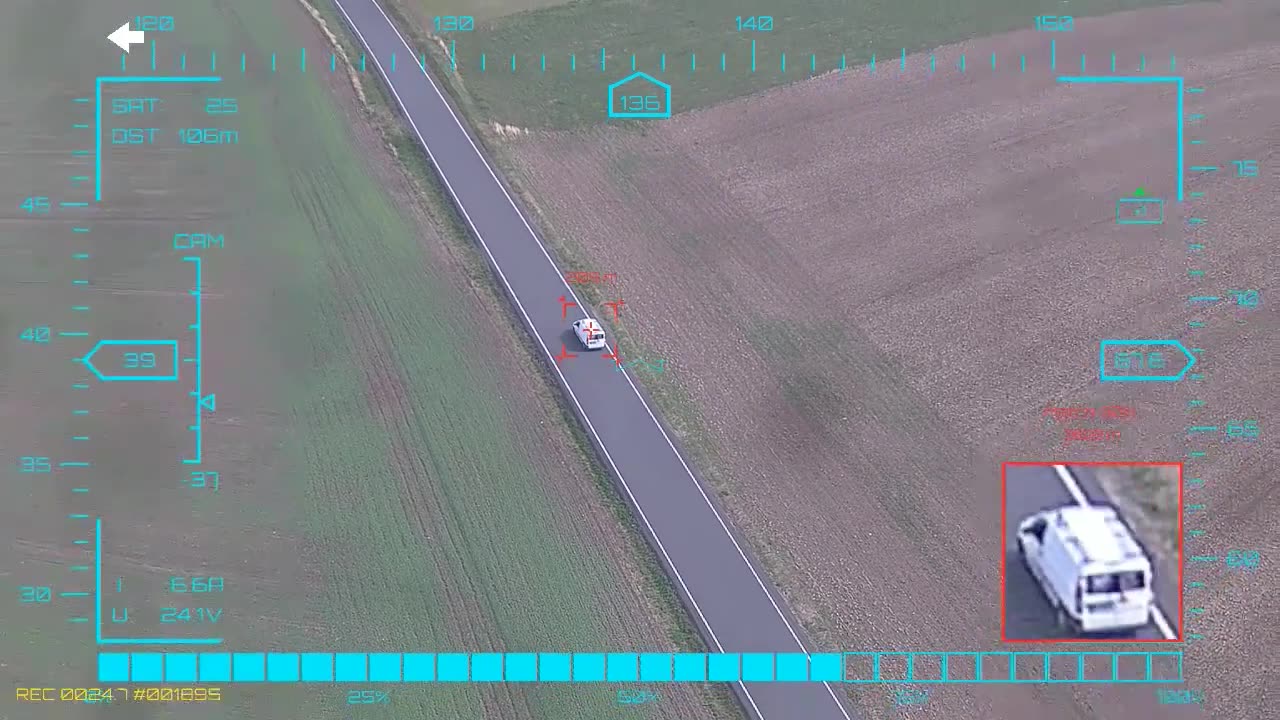
The operator — or the system — selects a single object; KestrelCV holds it through motion, vibration and scene change, with target-state information on the HUD.

Assist

Through the link they already have

The full perception overlay travels down the existing video link into goggles or ground station — the operator sees what the aircraft sees, decides and acts.

Onboard

No cloud, no lock-in

Runs headless on the airframe. Zero external services at inference — no continuous external-compute dependency.

Design doctrine

The selected target is priority #1 — designed for continuity through brief occlusion and scene disruption: resume the same track, not a new detection. The selected target remains the priority, and the picture reads expensive — because perception is trust.

03 · Technology

Software-defined mission payload

One perception core. Low latency. Two compute backends.

25–38ms
internal processing latency
2
compute backends · NVIDIA Jetson Orin, NXP i.MX 8M Plus
0
cloud calls at inference
1
video path · camera → operator
Portable

Runs anywhere

A hardware-agnostic software stack, flown on two very different compute modules: NVIDIA Jetson Orin Nano and NXP i.MX 8M Plus on a Toradex Verdin. It ports readily to any Linux hardware with MIPI CSI-2 camera inputs and a neural coprocessor, and scales onto more powerful or leaner silicon — the code doesn't change with the hardware.

Low latency

25–38 ms internal

Measured internal processing latency across both backends — low enough for a human to fly on and for the loop to close onboard. (Input-buffer to HDMI hand-off; sensor and video-link latency excluded.)

Through-channel

One video path

The perception overlay rides the existing video link — no second datalink, no cloud. The operator sees exactly what the aircraft perceives.

04 · Deployment

One perception core, two levels of operator control

One fast video channel — the operator chooses how much of the loop to hand over.

Operator-assisted

The HUD calls it out

A pure perception overlay painted into the goggles — the operator flies, the HUD marks what matters, in real time, over the link they already have. The operator picks the target and the system holds it.

AI co-pilot

The system finds, the operator commits

The system acquires and holds candidates on its own; the operator designates and commits. Machine speed for perception, human for the decision.

Next horizon

Fully autonomous systems — the same perception core closing the whole loop onboard, from search to hold, with people setting the mission and its rules.

05 · Proven in flight

It already flies

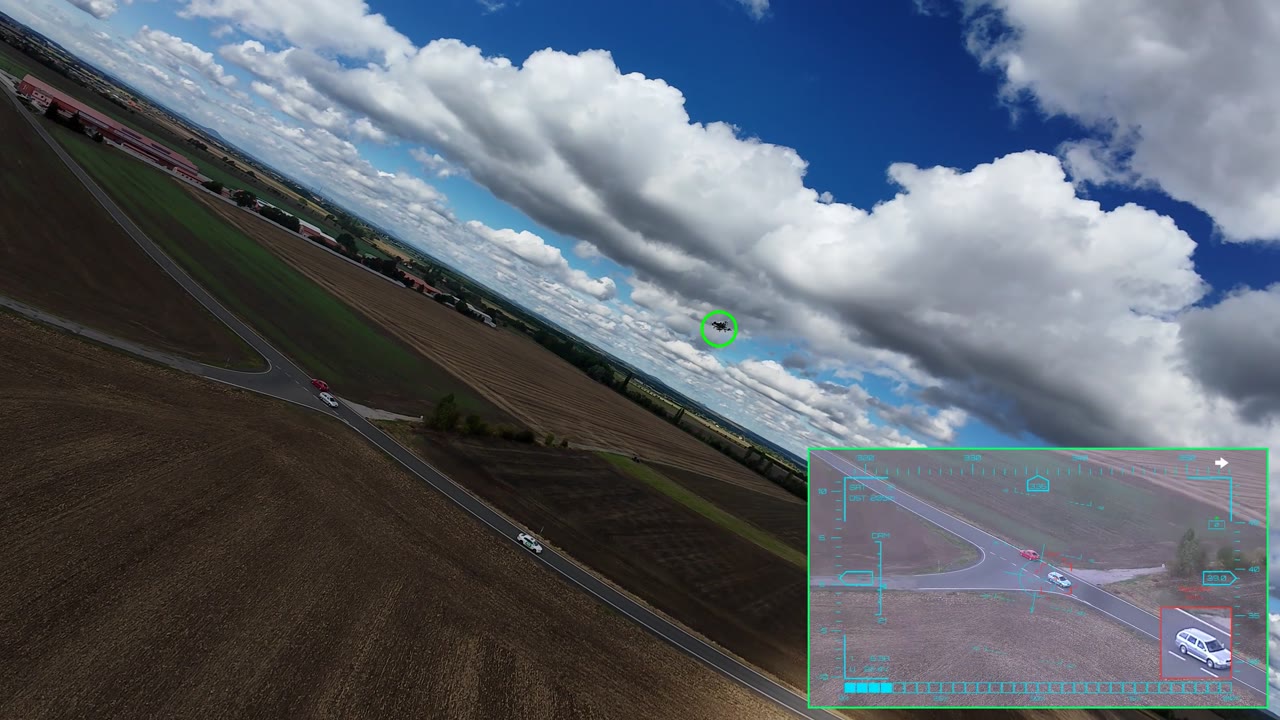
A demonstrator on a real airframe: it locks moving vehicles and holds them, with the perception HUD carried live into the operator's goggles over the video link. Every clip below is raw goggles DVR — no post-processing.

Whole-frame vehicle detection Single-target lock & hold HUD over the video link Software-only image stabilisation Flown on both compute backends
▶All clips in the flight gallery
06 · Missions & configurations

One core, defence-first & dual-use

One perception core keeps its picture onboard — degrading gracefully on a contested link rather than going blind.

The same core fits three camera configurations — the perception stays the same, the mount changes with the mission.

Light · FPV
Fixed camera

Hard-mounted camera with software image stabilisation. The configuration in the gallery.

As flown
Recon
Stabilised mount

Single-axis stabilised mount; the target lock feeds the mount, the mount keeps the target in frame.

With a mount partner
ISR
Gimballed

Three-axis gimbal steered by the lock, with target geolocation from GPS, attitude and camera angle.

With a gimbal partner
07 · Work with us

Built to sit inside someone else's platform

KestrelCV is a perception layer, not an airframe. It belongs on your carrier, behind your camera, in front of your operator. We are looking for partners on every side of that seam.

UAV makers & integrators

Perception for your airframe

KestrelCV as a payload module on your carrier: camera in, HUD and target state out over the video link you already fly. Compact compute, no cloud, your ground station, your branding. Integration starts with a test flight on your platform.

Gimbal & camera makers

A lock that steers

The single-target lock becomes the pointing input for your stabilised mount or gimbal: the AI holds the target, the mount follows. We already run attitude sensing and mount control inside the tracking loop and want to do it on your hardware.

Real-time vision

Custom vision systems

Fast video pipelines on embedded hardware: camera to display in tens of milliseconds, detection and tracking on NVIDIA Jetson or NXP i.MX, detectors trained on your own footage. Not only for aircraft — anything that has to see and react in real time.

Custom hardware

Carrier boards & electronics

Custom carrier boards for Jetson and i.MX modules, application-specific PCBs, video links, power and payload integration into the airframe. From schematic to a board that flies.

Tell us what you fly, or what you need to see — we answer with a plan and a date for a first test.

partners@kestrel.cv
08 · Company & contact
Company
Legal entitySTAVBY ELEKTRO TECHNOLOGIE s.r.o.
LocationCzech Republic · EU + NATO
NCAGE588FG
Software & productperception core, tracking, HUD
Hardwareelectronics, carriers, video links, integration
Contact

Partnerships, integration and engineering work:
partners@kestrel.cv

Everything else:
dev@kestrel.cv

Investors

KestrelCV is founder-funded to date. We are open to conversations with investors who know defence and dual-use hardware and want to see the system fly before the deck. invest@kestrel.cv